Robotic Joint Modules
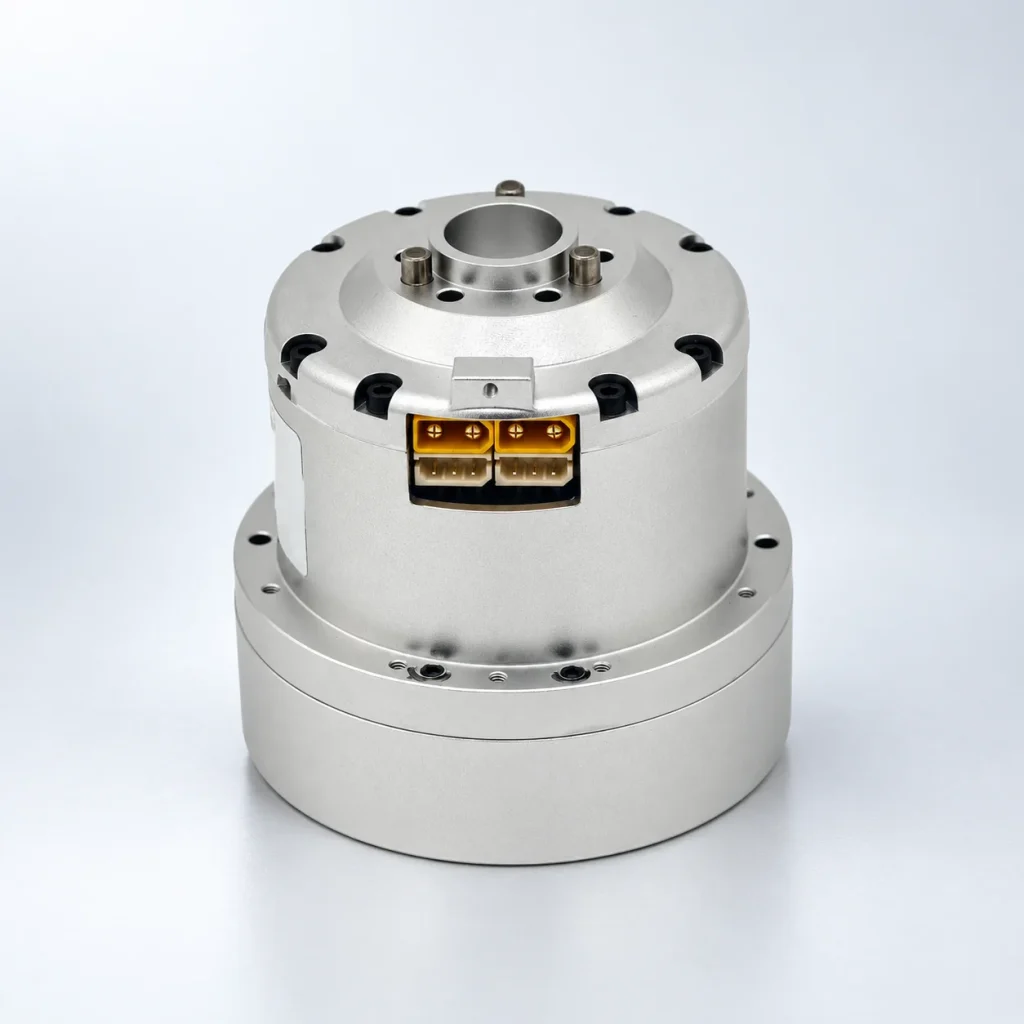
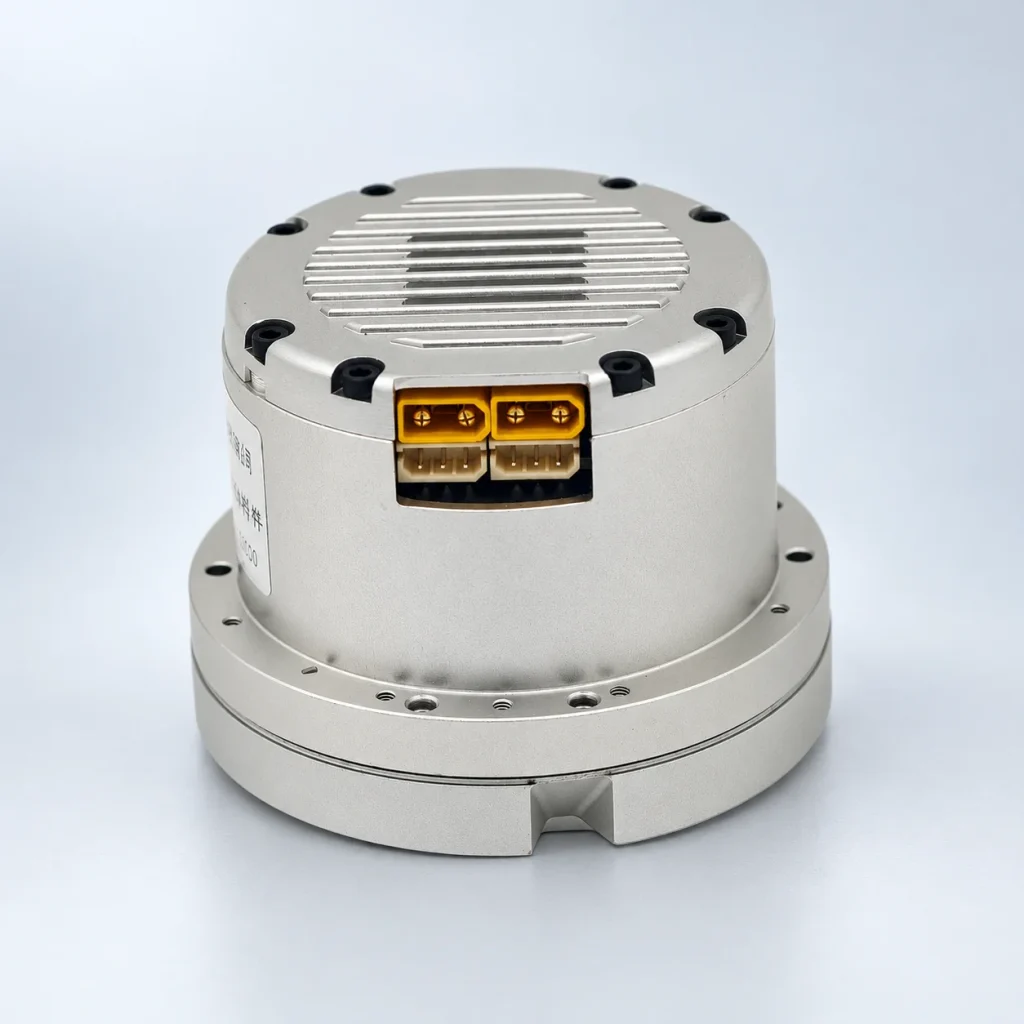
Compare the X01-010 and X01-020 integrated robotic joint modules. Both use planetary gear reducers and support CAN communication. Start with weight, dimensions and rated torque at 24V to assess your project integration requirements.
-
Add to wishlistAdd to wishlist
-
Add to wishlistAdd to wishlist
What is the difference between X01-010 and X01-020?
Both joint modules integrate a motor, planetary gear reducer, drive and absolute encoder. The comparison below focuses on weight, dimensions and rated torque to check during selection.
| Specification | X01-010 | X01-020 |
|---|---|---|
| Product details | View X01-010 | View X01-020 |
| Weight | 560g | 500g |
| Diameter × length | Ø76.5 × 81mm | Ø76.5 × 63mm |
| Rated torque (24V) | 9.55N·m | 6.0N·m |
| Standard operating voltage | DC 24V | DC 24V |
| Operating voltage range | DC 18—36V | DC 18—36V |
| Communication interface | CAN | CAN |
Assess applications using the laboratory-grade product documentation. Specifications depend on actual operating conditions; peak torque cannot substitute for rated torque. The official sales models are X01-010 and X01-020, listed as X01-01 and X01-02 respectively in the MetaDrive manual.
What should be confirmed before integration?
Please provide target torque and speed, range of motion, mounting space, power supply and control system information. Confirm the scope of supplied wiring, debugging tools and other accessories, along with any custom interfaces or hole positions, individually in the project plan.
Explore MetaDrive joint module documentation · Discuss joint integration requirements