MERIVUS / X01-020
Product overview
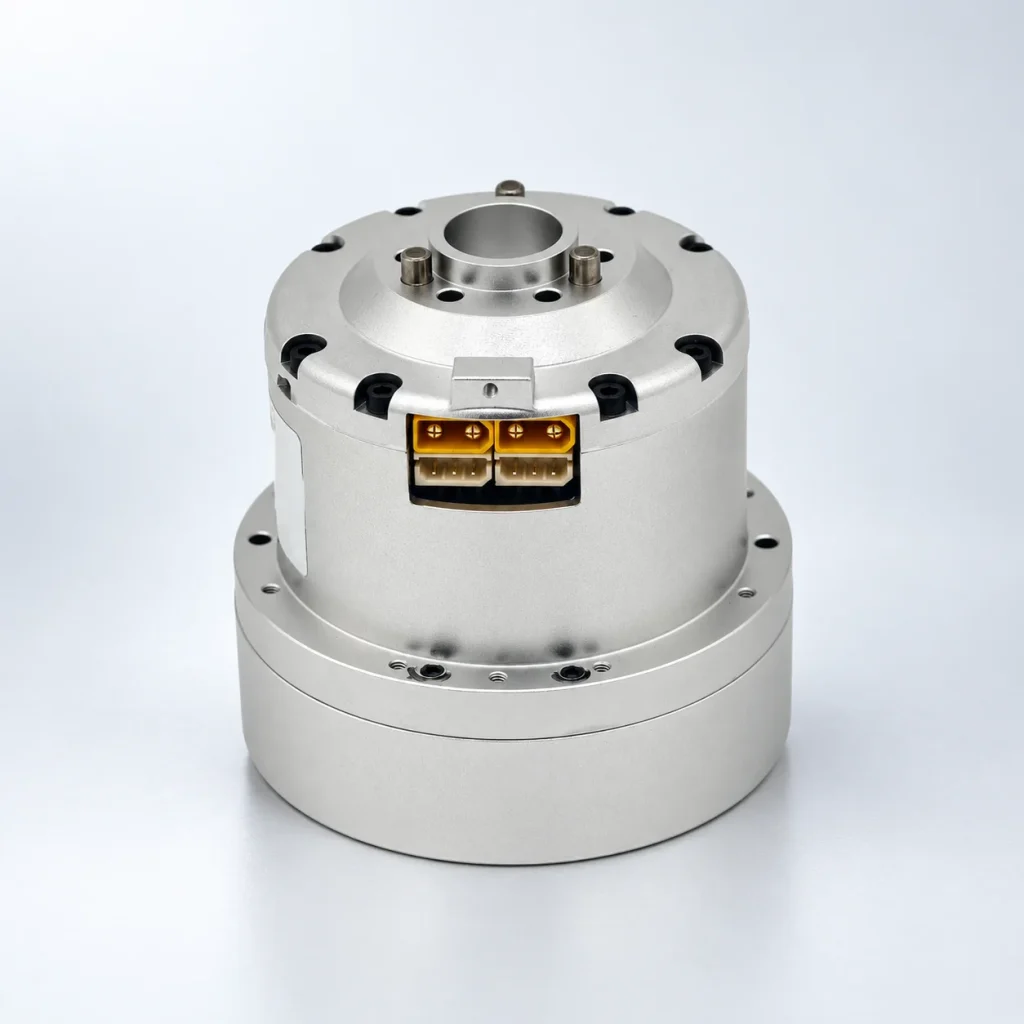
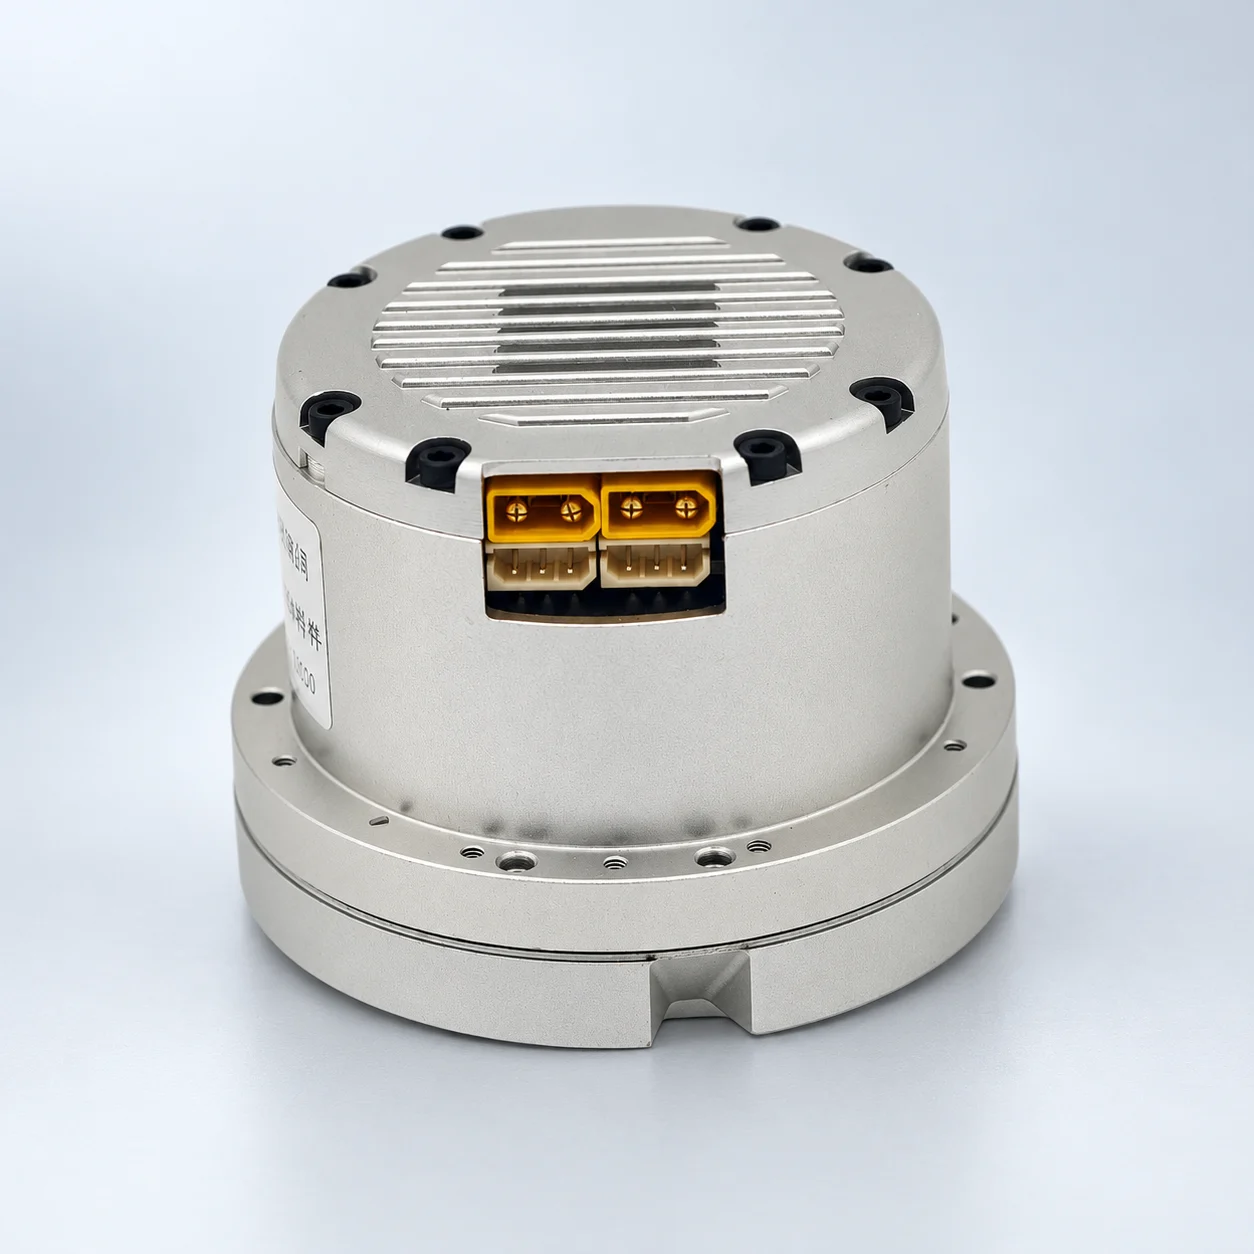
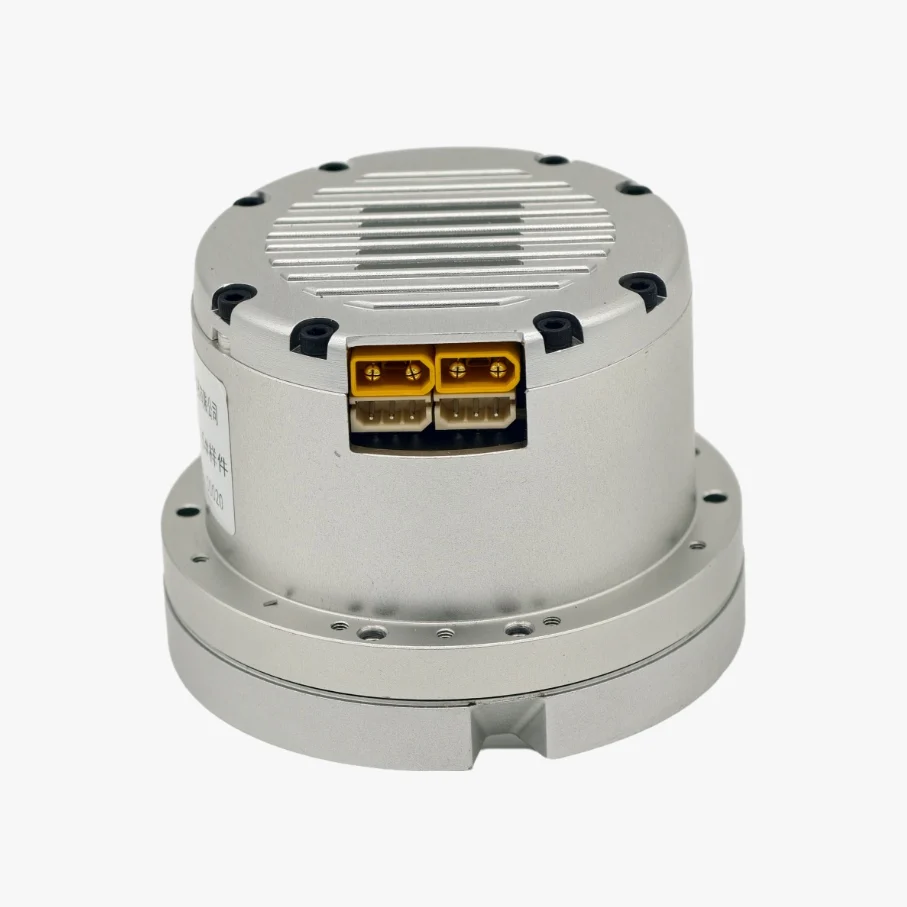
The X01-020 integrated robotic joint module combines a planetary gear reducer, frameless torque motor, servo drive and absolute encoder. Its standard operating voltage is 24V and rated torque is 6.0N·m (24V). Status can be read and control parameters sent over the CAN bus.
Integrated joint design
Integrates a planetary gear reducer, frameless torque motor, servo drive and absolute encoder.
CAN control and feedback
1Mbps communication baud rate and 1kHz communication frequency, supporting angle, angular velocity and torque commands with status feedback.
Defined Torque & Dimensions
Rated torque 6.0N·m (24V), peak torque 20N·m; diameter 76.5mm, length 63mm.
Specifications
| Official model | X01-020 |
|---|---|
| Purchase option | Standard silver version |
| Standard operating voltage | DC 24V |
| Operating voltage range | DC 18—36V |
| Weight | 500g |
| Dimensions (diameter × length) | Ø76.5mm × 63mm |
| Rated torque | 6.0N·m(24V) |
| Peak torque | 20N·m |
| Maximum speed | 15.3rad/s(24V) |
| Motor rated current (RMS) | 5.0A |
| Maximum motor current (RMS) | 18A |
| Maximum motor phase current (Peak) | 30A |
| Joint torque constant | 0.88N·m/A |
| Motor back-EMF constant | 6.4Vrms/krpm |
| Motor line resistance | 0.52(1±5%)Ω |
| Motor line inductance | 0.32(1±10%)mH |
| Gearbox type | Planetary gears |
| Absolute encoder | 14-bit |
| Communication interface | CAN |
| Communication baud rate / frequency | 1Mbps / 1kHz |
| Direction of rotation | CW / CCW (viewed from the output shaft end) |
| Control commands | Angle P, angular velocity V, torque T, stiffness Kp, damping Kd |
| Status feedback | Angle, angular velocity, torque, driver temperature and motor temperature |
Specifications are provided under the ideal environmental conditions stated in the product manual. Actual results may vary with power supply, load and operating conditions. Rated and peak torque should be assessed separately during selection.
Dimensions & Mounting
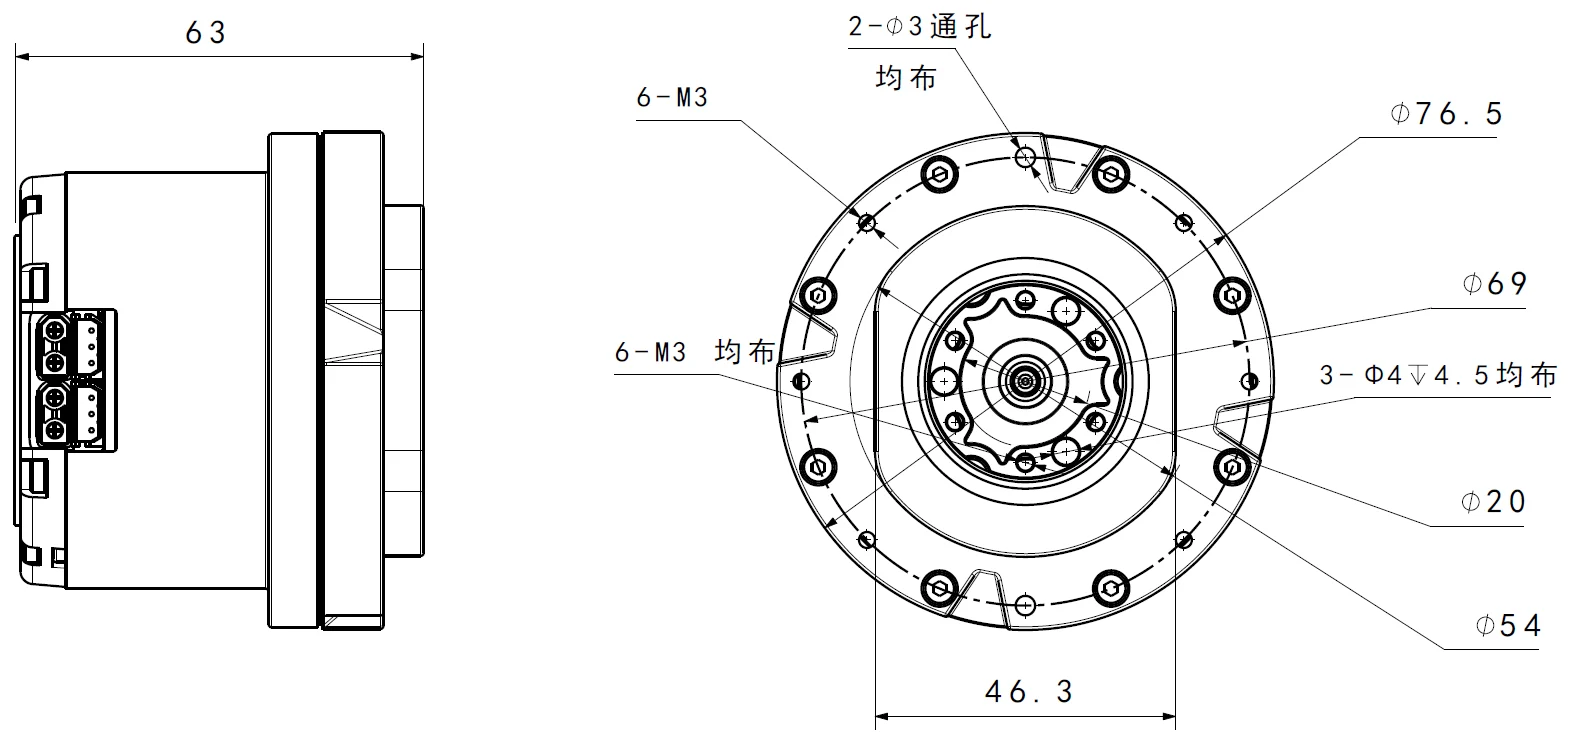
Use the units indicated in the drawing. Check the interfaces against the available installation space before assembly.
Applications and selection
For robotic arm and joint selection, prototype development and system integration. Assess each application against its load, range of motion, mounting structure and control system.
For inquiries, provide the target torque, speed, joint installation space, power supply and control requirements. Before installation, check the mechanical interfaces, connectors and wiring definitions, and select fasteners for the actual operating conditions.
Supply and customization
The sales configuration is a standard silver joint module. Confirm the scope of supply for wiring harnesses, commissioning tools and other accessories when making an inquiry.
Housing appearance, interfaces, flanges, mounting holes and torque targets can be discussed for your project. Standard and custom configurations are quoted separately. Technical configuration, supply scope and lead time are confirmed by both parties.
Selection Notes & Resources
The X01-020 weighs 500g, is 63mm long and has a rated torque of 6.0N·m at 24V. Its weight and dimensions differ from the X01-010. Selection still requires checking the load, control interfaces and mounting conditions. Both models are assessed against laboratory-grade product specifications.
Compare with the X01-010 joint module · View the specifications for both models · Discuss joint integration requirements